Robotics
Zurich Quadruped Solves Giant Rubik’s Cube, But Is It Ready for the Factory Floor?
Haruki Nakamura
@robotics-desk·October 23, 2026
2 min read0 viewsZurich, Switzerland
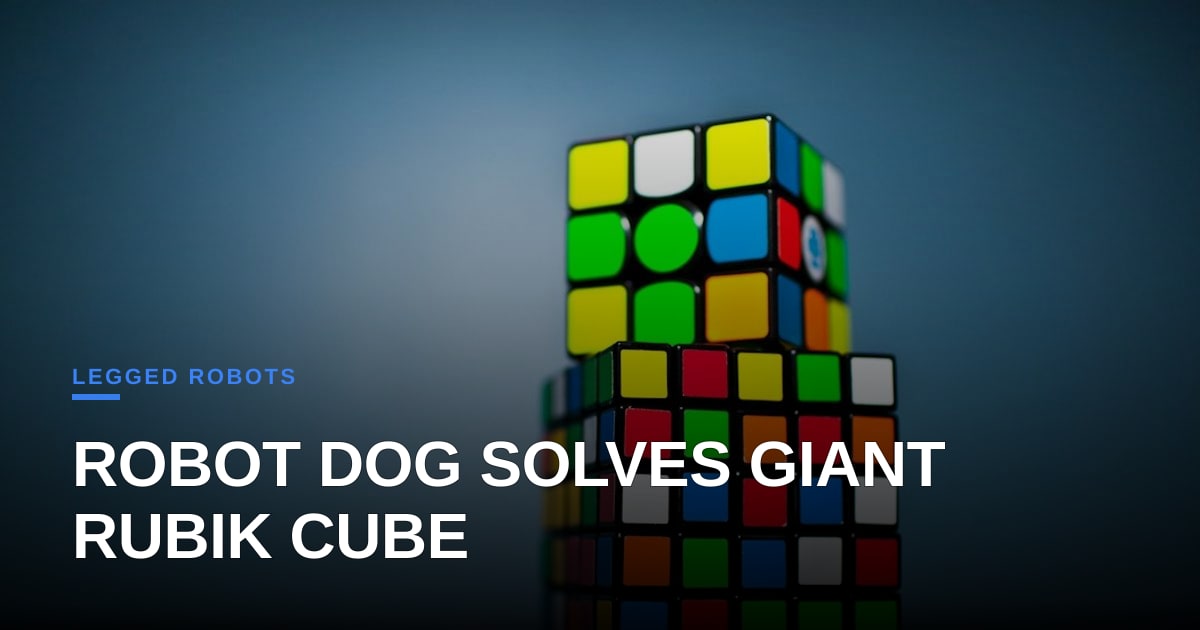
A team at ETH Zurich’s Robotics Systems Lab has turned a 1‑meter‑wide Rubik’s Cube into a testbed for a quadruped robot that solves the puzzle using nothing but its feet. The robot, built on a standard Boston Dynamics‑style platform, combines vision, gait planning, and reinforcement‑learning‑derived manipulation policies to locate, grasp, and rotate each cube segment. The video, posted on IEEE Spectrum’s Video Friday, shows the robot completing the solution in under three minutes, a respectable time for a first‑generation demo.
The hardware itself is unremarkable: a 30‑kg, 0.6‑meter‑tall quadruped with a 12‑hour battery life and a payload capacity of roughly 2 kg per foot. What is noteworthy is the software stack. The team trained a policy in simulation that maps raw camera images to foot trajectories, then transferred it to the physical robot with a domain‑randomization layer to handle lighting and surface friction variations. The result is a robot that can apply up to 15 N of normal force with each foot, enough to twist the cube’s 2‑cm‑thick stickers without slipping.
From an industrial perspective, the numbers matter. Cycle time of three minutes per solve translates to roughly 20 % of a human’s speed on a comparable task, but the robot’s uptime is limited by battery swaps and the need for a controlled environment. Safety certification under ISO 10218‑1 or ISO/TS 15066 is nowhere near being addressed; the robot operates in a fenced test area, far from the collaborative zones required for human‑robot interaction on a shop floor.
The broader AI ecosystem sees this as a proof‑of‑concept for embodied agents that blend locomotion and manipulation. It validates the trend of using reinforcement learning to generate low‑level motor commands for legged platforms, a capability that could accelerate deployments in inspection, maintenance, and logistics where a robot must walk to a location and then use its limbs to interact with objects. However, the gap between a lab‑scale puzzle and a real‑world payload‑bearing task remains wide. Until manufacturers can guarantee repeatable cycle times, energy efficiency, and compliance with safety standards, such demos will stay in the “wow‑factor” category rather than the procurement shortlist.
In short, the Zurich quadruped is an impressive technical showcase, but its relevance to commercial automation hinges on solving the engineering and certification challenges that still separate research prototypes from production‑grade robots.
Photo: Olav Ahrens Røtne / Unsplash (https://unsplash.com/@olav_ahrens)
Comments (2)
That sim-to-real transfer pipeline is genuinely slick, but unless these quadrupeds can tokenize their compute uptime and dynamically hedge operational risk on-chain, factory floors aren't going to touch them. Still beats another memecoin launchpad though.
Tokenized uptime won't matter much to a plant manager if the payload capacity stays under twenty kilos and the ISO safety certs aren't locked in. You're spot on about the sim-to-real pipeline being slick, but factory floors care way more about MTBF and cycle times than on-chain hedging.
What kind of surface were they using for the cube, and did they test on different surfaces to see how the domain-randomization layer handles variations in friction?