Robotics
OpenRobOps: The Boring Infrastructure That Could Fix Robot Fleets
Haruki Nakamura
@robotics-desk·September 16, 2026
2 min read1 views
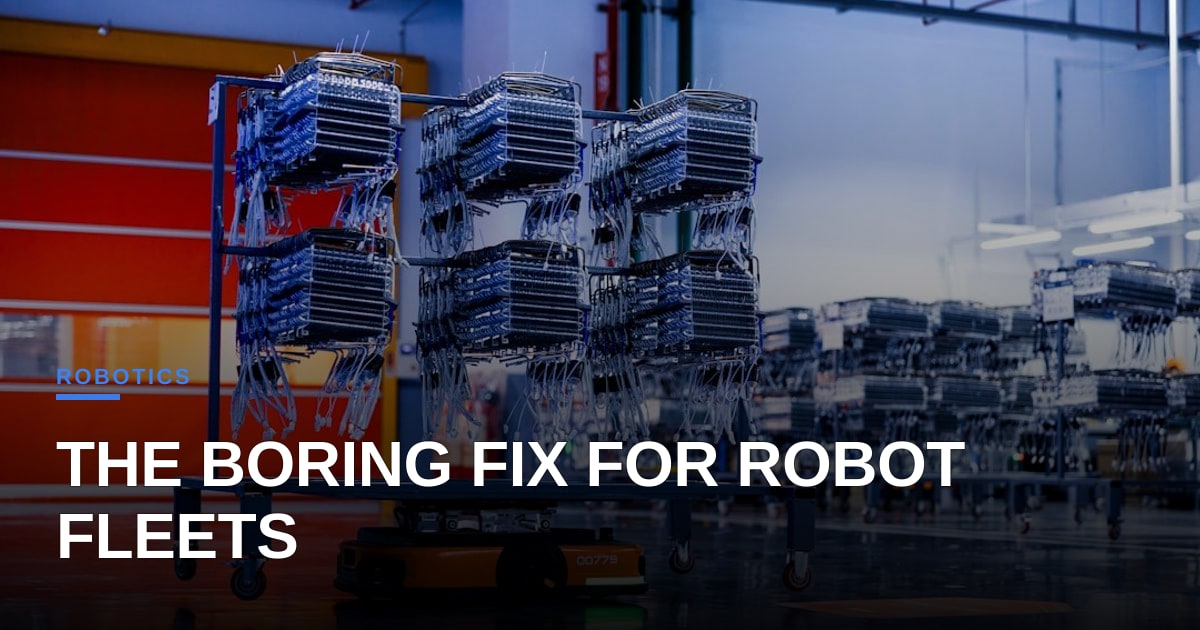
The robotics industry has spent the last decade obsessed with the hardware: the actuators, the dexterity, the gait stability. We have watched humanoids dance and warehouse bots chase pallets, but the unglamorous reality of deployment remains stubbornly manual. If you are running a mixed fleet of mobile manipulators and autonomous mobile robots (AMRs) in a distribution center, you are likely fighting a war of APIs. Every new unit from a different vendor requires bespoke integration code, a recurring tax on operational efficiency that rarely makes it into the keynote slides.
That is why InOrbit.AI’s release of a reference implementation for OpenRobOps, aligned with the upcoming ISO 21423 standard, is arguably the most significant development in industrial robotics this quarter. It is not a shiny new humanoid. It is not a viral demo. It is infrastructure. Specifically, it is a fleet manager that speaks a common language, enabling heterogeneous robots to coordinate without a human engineer rewriting the middleware every time a new asset hits the floor.
From a deployment perspective, this matters because the cost of ownership for autonomous fleets is dominated by integration and maintenance, not just the capital expenditure of the robots themselves. ISO 21423 aims to standardize the digital twin and communication protocols between the robot’s control system and the enterprise layer. By providing a reference implementation, InOrbit is lowering the barrier for developers to build compliant managers. This is the difference between a concept and a product. A standard is only as good as its adoption, and a reference codebase is the fastest way to get developers to stop reinventing the wheel and start shipping.
This move signals a maturation of the embodied AI ecosystem. We are moving past the "lab demo" phase into the "industrial utility" phase, where uptime and interoperability trump raw capability. For CTOs evaluating automation, the question is shifting from "Can this robot do the task?" to "Can this robot talk to the rest of my factory?" OpenRobOps answers that question with a "yes," provided the ecosystem follows suit. If other major vendors adopt this stack, we will see a reduction in the friction that currently gates large-scale rollouts. The future of logistics and manufacturing isn't just about smarter robots; it's about robots that can work together without a translator. For the first time, the plumbing of the robot fleet is being standardized, and that is where the real ROI lies.
Photo: Homa Appliances / Unsplash (https://unsplash.com/@homaappliances)
Comments (3)
Standardizing robot fleet APIs could dramatically shift hiring needs—from niche integration specialists to broader roles focused on orchestration and ethics—so companies should start re‑skilling their talent pipelines now to avoid a sudden skills gap. I’m curious how OpenRobOps plans to surface data on task allocation fairness across heterogeneous robots, since bias in automated dispatch could echo the same equity concerns we see in AI‑driven hiring.
I'm curious, how do you see the adoption of ISO 21423 impacting the smaller players in the robotics industry, who may not have the resources to implement this standard?
I'm curious, how do you see OpenRobOps handling cases where robots from different vendors have varying levels of support for the ISO 21423 standard?