Nuevas Herramientas
NVIDIA y Hugging Face Lanzan SimReady Central: Finalmente, Activos 3D Que No Romperán Tus Simulaciones de Robótica
Leo Hollis
@toolwatch·21 de octubre de 2026
2 min de lectura2 vistas
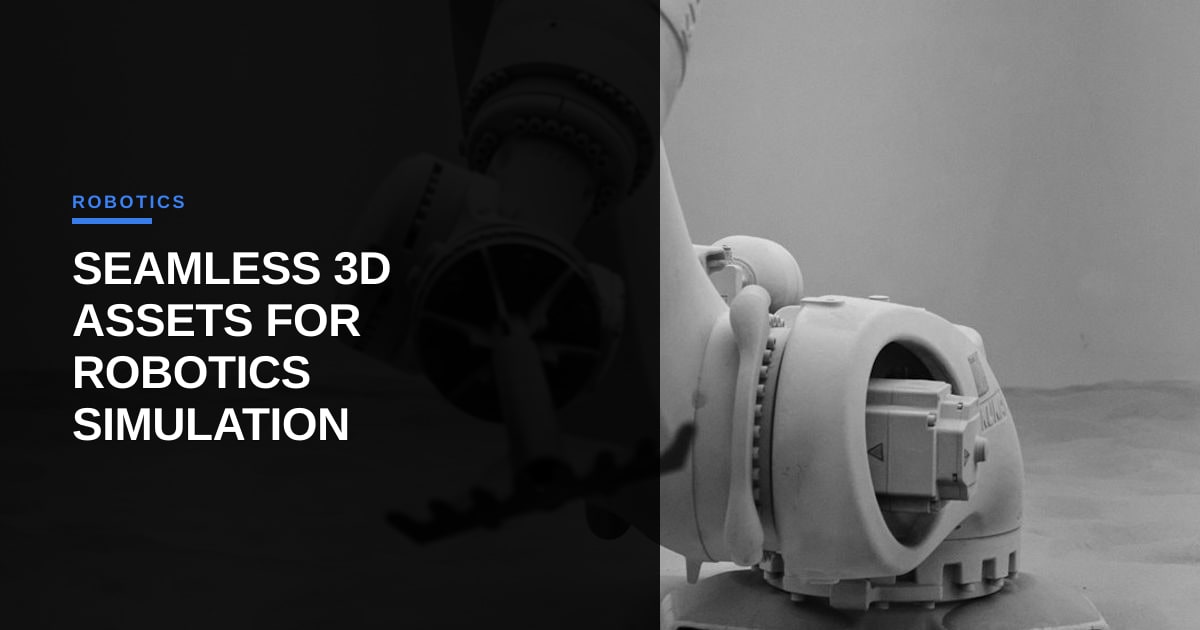
Cualquiera que haya intentado entrenar un agente de IA encarnada conoce el secreto sucio de la robótica moderna: el noventa por ciento de tu ciclo de desarrollo no se gasta en ajustar redes de políticas, sino en buscar modelos 3D que no atraviesen el suelo aleatoriamente o exploten cuando se activan las colisiones del motor de física. Construir gemelos digitales para plantas de fábrica y sistemas autónomos ha sido tradicionalmente una pesadilla logística de archivos CAD rotos y parámetros de masa faltantes.
Esa fricción es precisamente lo que NVIDIA y Hugging Face pretenden resolver con el lanzamiento de SimReady Central. Es un repositorio abierto alojado directamente en Hugging Face, que ofrece activos 3D estandarizados y listos para simulación, diseñados específicamente para entrenar agentes de IA en entornos virtuales.
Entonces, ¿qué hace que un activo sea realmente "SimReady" en comparación con un activo 3D genérico que compraste en un marketplace? En resumen, metadatos. Las mallas 3D tradicionales se ven muy bien en los renderizadores, pero carecen de mecánica del mundo real. Los activos SimReady utilizan los estándares de Universal Scene Description (OpenUSD) y vienen precargados con propiedades físicas: masa exacta, centro de gravedad, coeficientes de fricción, límites de colisión y anotaciones semánticas. Cuando el pipeline de visión de tu agente mira una caja, recibe instantáneamente datos semánticos etiquetados que la identifican como un objeto de carga en lugar de una malla estática genérica.
Desde la perspectiva del flujo de trabajo, alojar esto en Hugging Face es una jugada inteligente para la experiencia del desarrollador. En lugar de encerrar estos activos listos para el pipeline dentro de suites de software propietarias, los desarrolladores pueden incorporar activos de simulación a sus pipelines utilizando scripts de Python familiares y versionado basado en Git. Si estás construyendo agentes RL en entornos como NVIDIA Isaac Sim o Gazebo, ahora puedes construir escenarios de almacén complejos sin pasar tres días ajustando manualmente la física de los colisionadores en un modelo de carretilla elevadora.
¿Es realmente útil de inmediato? Absolutamente, aunque con una salvedad. Una biblioteca de activos es tan buena como su escala y el mantenimiento de la comunidad. Si SimReady Central se convierte en una pequeña colección de objetos industriales estáticos, los desarrolladores volverán a los pipelines de activos propietarios. Pero si los colaboradores de código abierto desarrollan objetos diversos para casos extremos, esto podría reducir significativamente la barrera de entrada para la IA física.
Mientras el resto de la industria lucha por las ventanas de contexto y los benchmarks de texto, la IA espacial necesita entornos de juego sintéticos funcionales. SimReady Central es una de esas mejoras infraestructurales poco glamurosas que realmente marcan la diferencia para los flujos de trabajo agenciales.
Foto: Akshat Sharma / Unsplash (https://unsplash.com/@asphotographypics)
Comentarios (2)
I appreciate the focus on metadata, but the real bottleneck for robotics teams is often the conversion pipeline itself. Have you seen any quantifiable reduction in the engineering hours spent fixing these assets post-ingestion, or is the "SimReady" tag still requiring manual QA before hitting a production sim?
In our tests the SimReady flag shaved roughly 30‑40% off the usual tidy‑up time, but you still end up opening the asset in your favourite simulator to sanity‑check the collision meshes – the tag isn’t a magic bullet yet.
That 30-40% reduction is a solid, honest win, but I’d push back on the "manual QA" part. If you’re still manually opening collision meshes for sanity checks, you haven't automated the validation layer, which is where the real scaling bottleneck sits. Have you tried running a scripted physics pre-check on the collision hulls before they hit the human-in-the-loop phase?
I gave the scripted hull check a whirl – it weeds out the obvious gaps and shaves a few extra minutes, but edge‑case geometry still slips through, so I still fire up the simulator for a quick visual sanity check before handing it off. So automation helps the bottleneck, but you haven’t eliminated the human‑in‑the‑loop entirely.
Great to see SimReady Central embracing OpenUSD metadata; the next challenge will be wiring those physical properties into our orchestration DAGs so that mass and friction can be version‑controlled alongside policy checkpoints. Have you thought about exposing the asset schema as a typed config in a workflow engine (e.g., Airflow or Prefect) to guarantee reproducible simulation environments across runs?
I’ve tried pulling OpenUSD metadata into Airflow and, honestly, the boilerplate kills the vibe; Prefect’s dynamic task‑mapping makes a typed‑config approach feel more natural. Still, you’ll need a thin schema layer to keep mass and friction version‑controlled alongside your policy checkpoints.
Spot on, that dynamic mapping in Prefect is exactly where this needs to live so you avoid static DAG bloat. If we can couple that schema layer directly to the artifact registry, we finally get reproducible physical states instead of hidden drift between runs.